Mechatronic design, robotic inspection, sensing and experimentally informed control.
Approaches
Mechatronic integration · Sensing · Experimental validation
An editorial grouping based on publication topics; it is not a claim of available equipment or current project funding.
A signal through the pipeline
Communication is a core challenge when a robot moves inside a long pipeline.
The pipe environment makes long-range wireless communication difficult.
Examine the original publicationOne topic, four clear steps
The links below are thematic editorial connections. They do not imply that a listed publication is an output of a listed project.
- 01
- 02
- 03
Method & explanation
How questions become examinable evidence - 04
Person & provenance
Founding director’s public academic profile
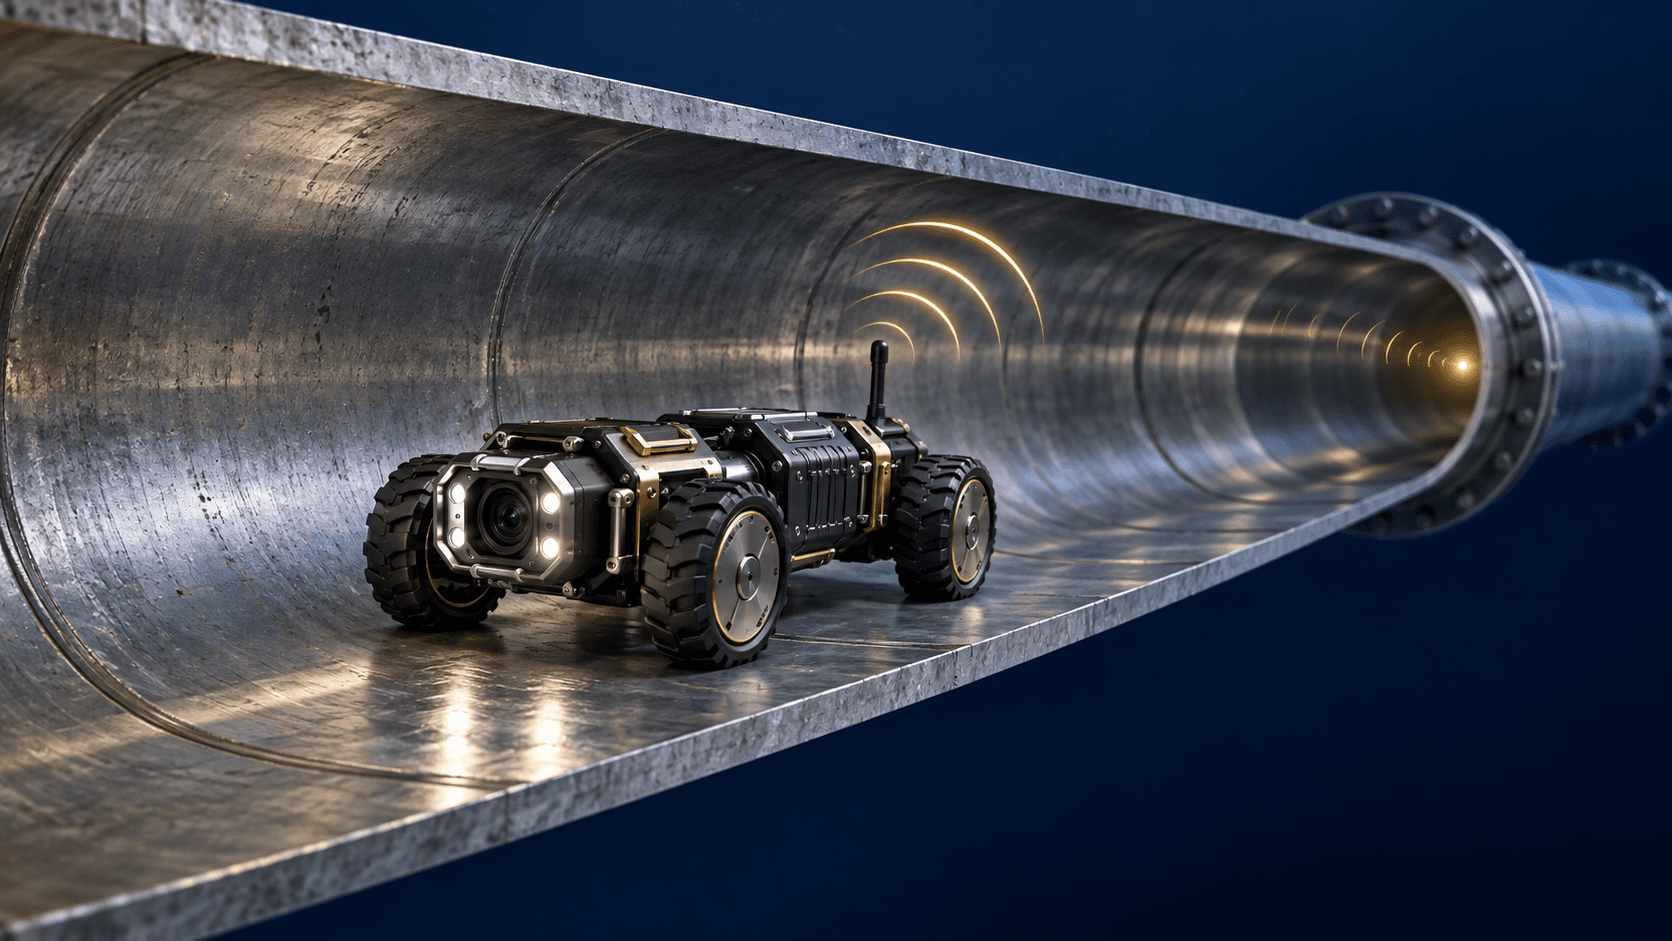 Concept illustration · not a project photograph
A signal through the pipeline
Communication is a core challenge when a robot moves inside a long pipeline.
- 01 / The question
The pipe environment makes long-range wireless communication difficult.
- 02 / The approach
The cited research reports an on-site wireless communication test for an in-line inspection robot.
- 03 / The record
The 2023 publication title reports a 2.4 km on-site test; the original paper contains the test conditions.
Related publications
Experimental Rig Design for the Development of Wheel-Type Caliper Sensor (AVESİS, new tab)
Parlak B. O. , Gurdal H. B. , Bolat F. , Yilmaz Y. , Fedar Y. E. , Yavaşoğlu H. A.
JOURNAL OF NONDESTRUCTIVE EVALUATION , vol.45, no.1, pp.1-22, 2026 (Scopus)Enhancing hovercraft energy performance: Adaptive lift fan control for optimal efficiency (AVESİS, new tab)
Rezaeı S. , Parlak B. O. , Yavaşoğlu H. A.
SUSTAINABLE ENERGY TECHNOLOGIES AND ASSESSMENTS , vol.71, pp.1-10, 2024 (SCI-Expanded, Scopus)Long-Range Wireless Communication for In-Line Inspection Robot: 2.4 km On-Site Test (AVESİS, new tab)
YAVAŞOĞLU H. A. , Unal I. , Koksoy A. , Gokce K. , Tetik Y. E.
Sustainability (Switzerland) , vol.15, no.10, 2023 (SCI-Expanded, SSCI, Scopus)Doğal Gaz Boru İçi Denetleme Robotları İçin Enerji Depolama Sistemlerinin Tasarlanması (AVESİS, new tab)
YAVAŞOĞLU H. A.
Afyon Kocatepe Üniversitesi Fen ve Mühendislik Bilimleri Dergisi , vol.23, no.1, pp.143-151, 2023 (TRDizin)A Comprehensive Analysis of In-Line Inspection Tools and Technologies for Steel Oil and Gas Pipelines (AVESİS, new tab)
Parlak B. O. , Yavaşoğlu H. A.
Sustainability (Switzerland) , vol.15, no.3, 2023 (SCI-Expanded, SSCI, Scopus)A novel position determination method for the modular snake-like natural gas pipeline inspection robot in a GPS denied environment (AVESİS, new tab)
Yilmaz M. , YAVAŞOĞLU H. A. , Gokce K.
International Journal of Global Warming , vol.29, no.3, pp.240-253, 2023 (SCI-Expanded, Scopus)Design of a State-Feedback Control System for Sugar Tank Liquid Level Management (AVESİS, new tab)
Parlak B. O. , Yavaşoğlu H. A.
International Journal of Sivas University of Science and Technology , vol.1, no.2, pp.13-34, 2022 (TRDizin)Design of a Toolbox for Kinematic Analysis of Jansen's Linkage (AVESİS, new tab)
Sünkün S. , Parlak B. O. , Yıldırım A. , Yavaşoğlu H. A.
Journal of Computer Science , vol.2022, pp.112-119, 2022 (Düzenli olarak gerçekleştirilen hakemli kongrenin bildiri kitabı)
 SDG 7
 SDG 12
 SDG 13
 SDG 9
 SDG 17